English
 Español
 Deutsch
 日本語
 Polska
 Français
 한국의
 Українська
 Italiano
 Nederlands
 Türkçe
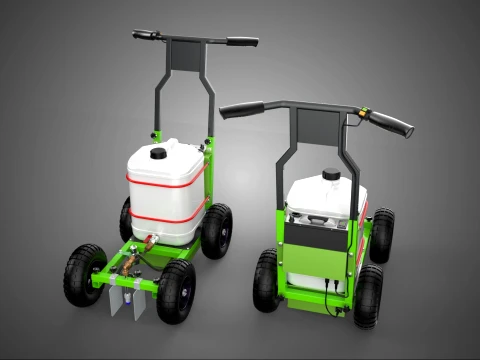
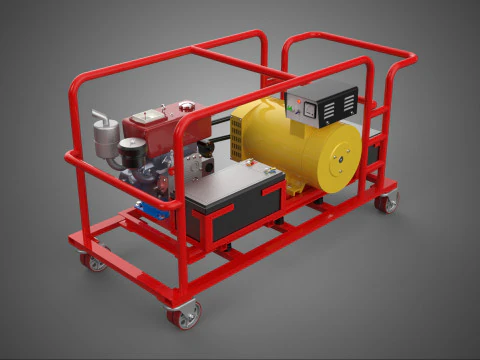
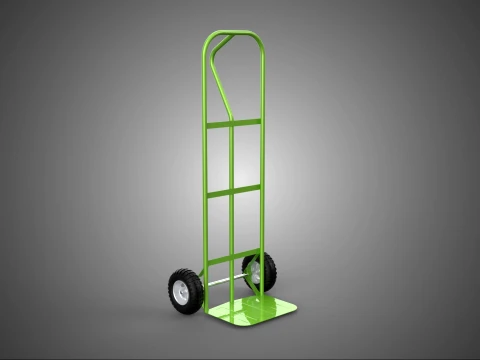
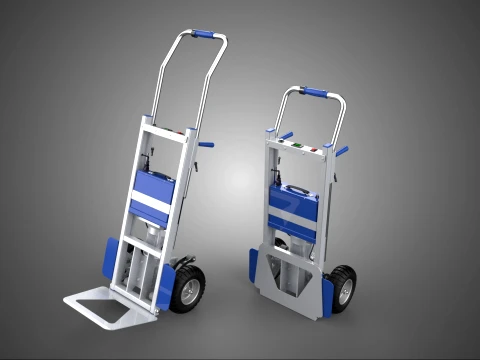
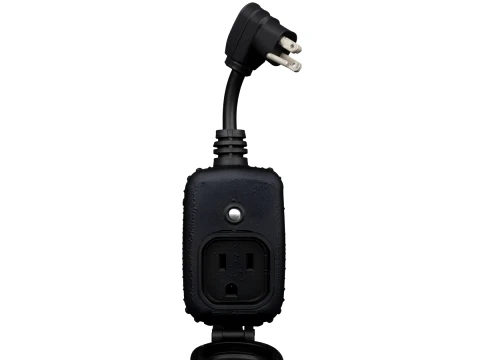
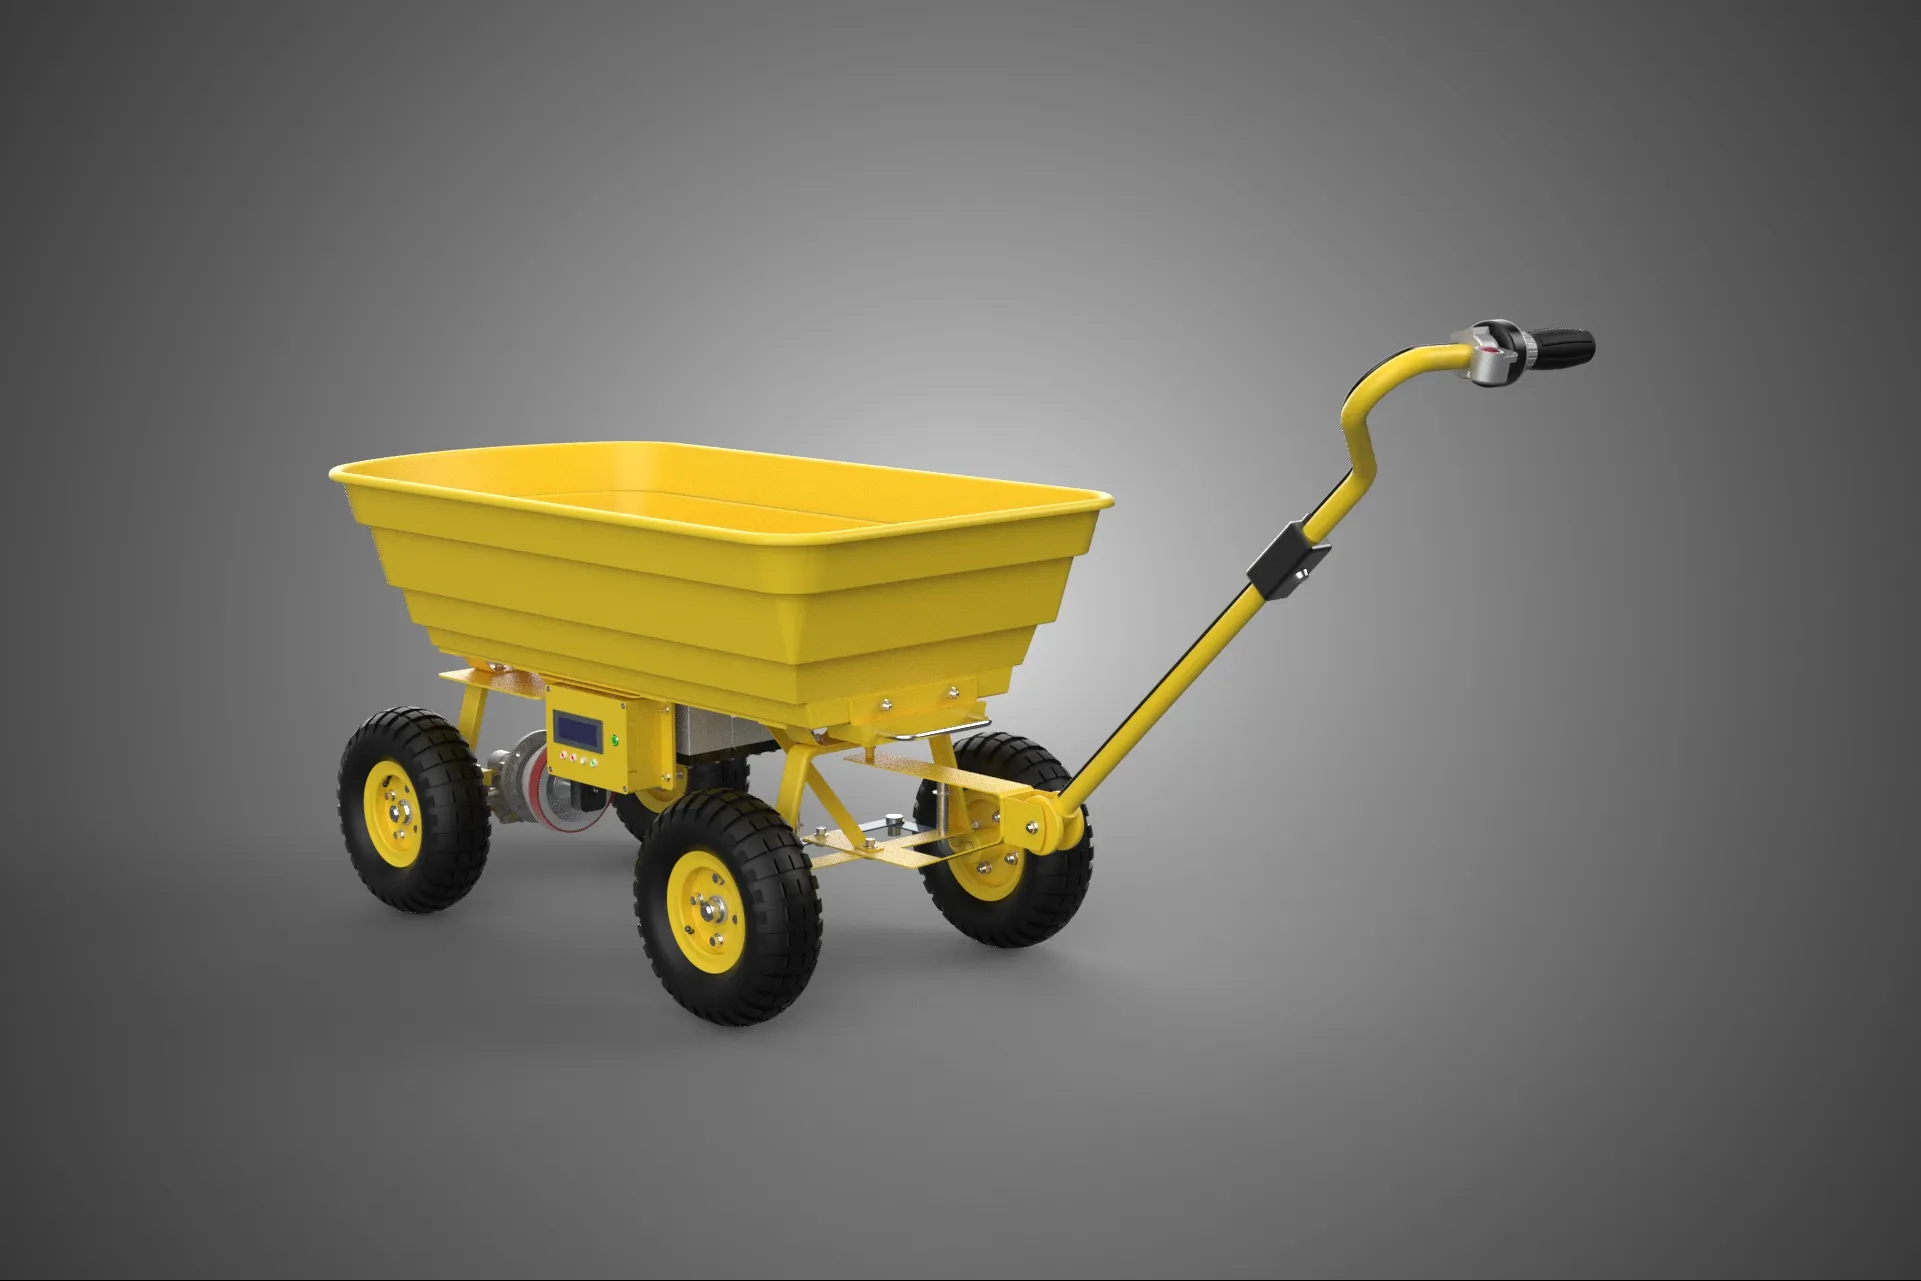
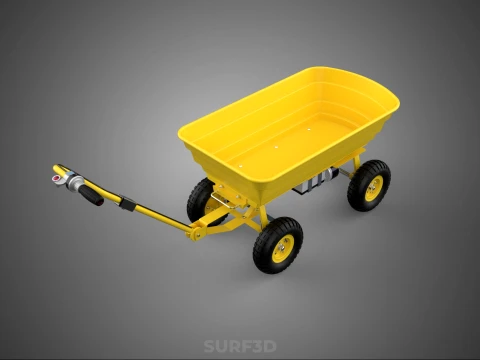
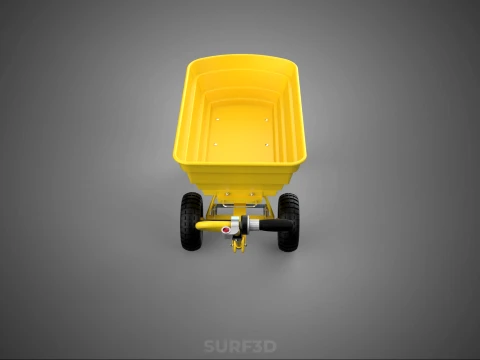
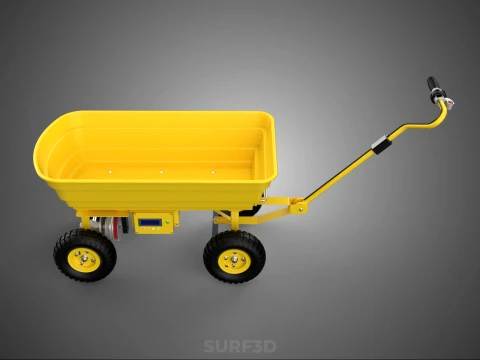
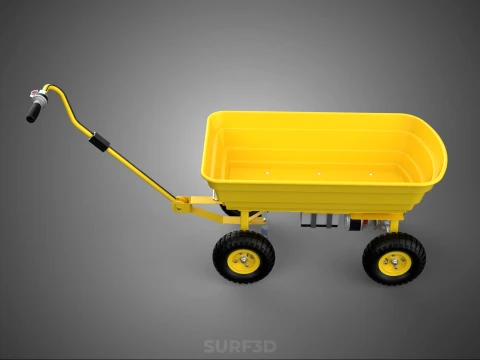
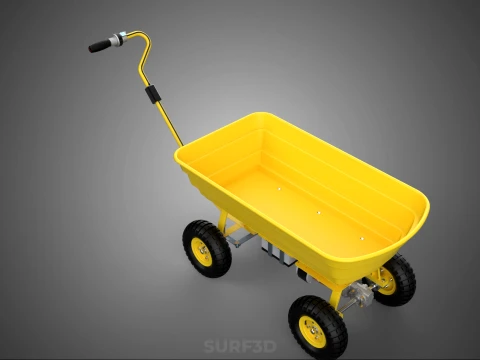
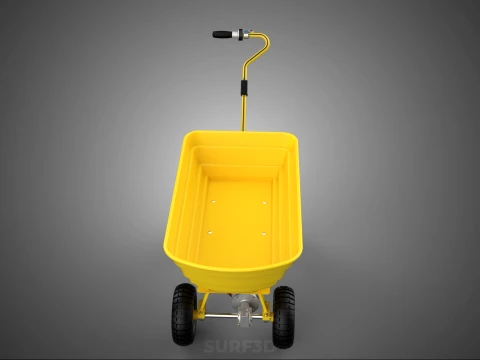
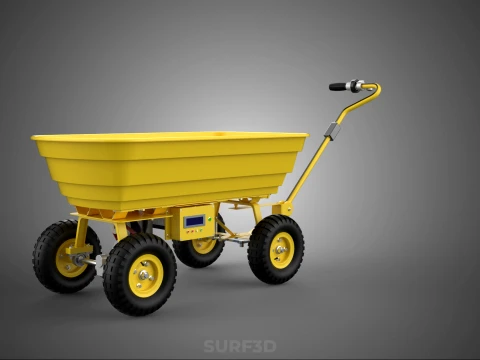
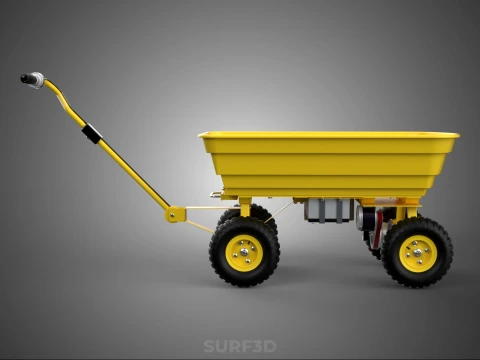
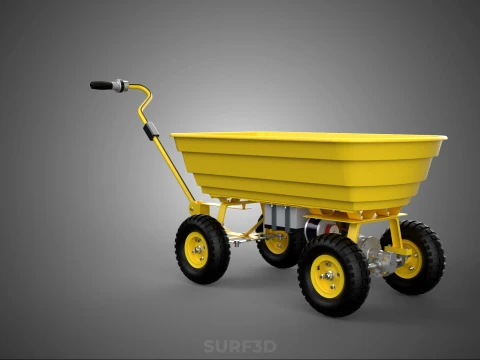
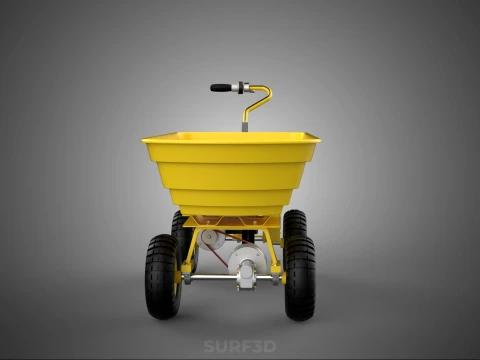
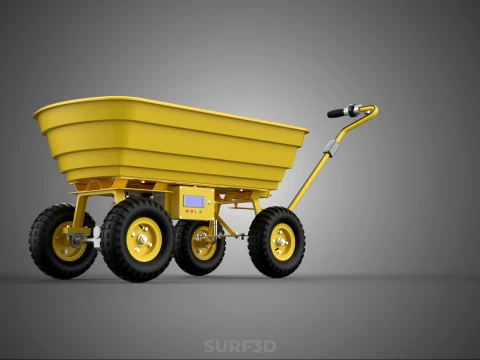
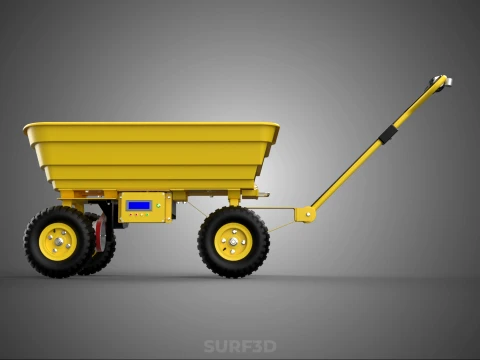
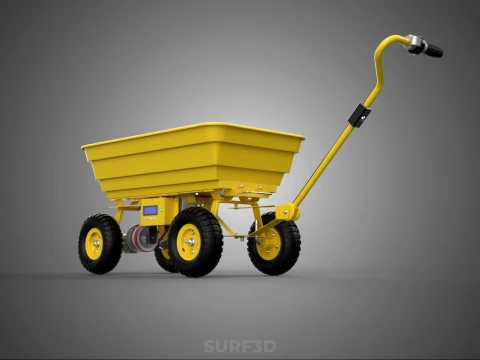
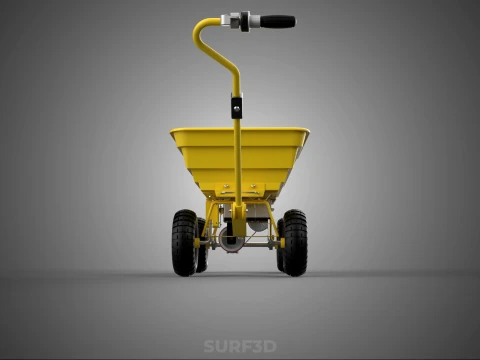
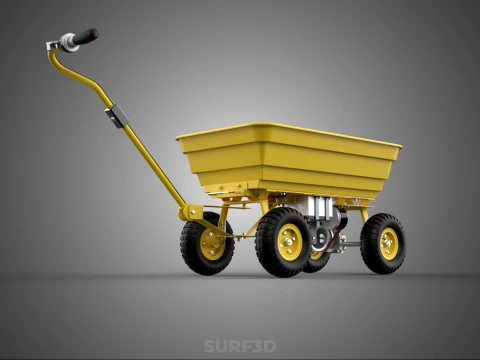
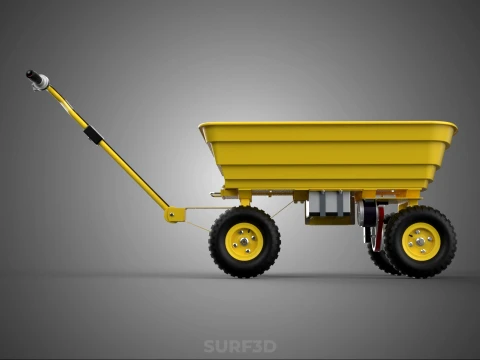
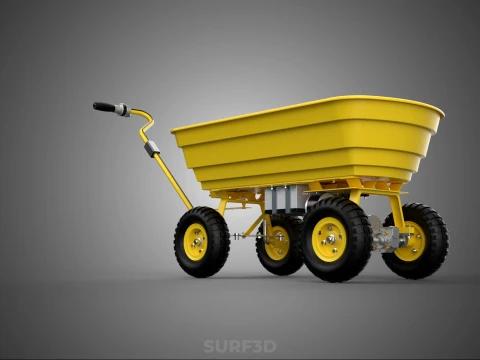
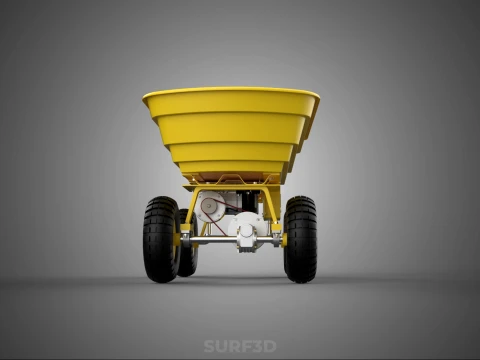
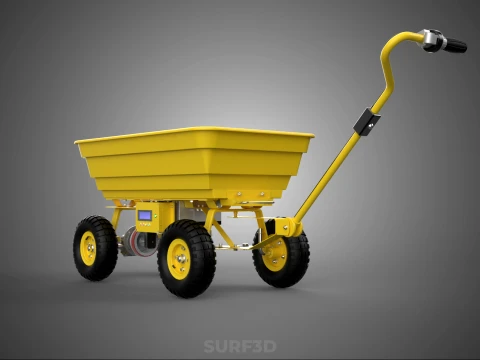
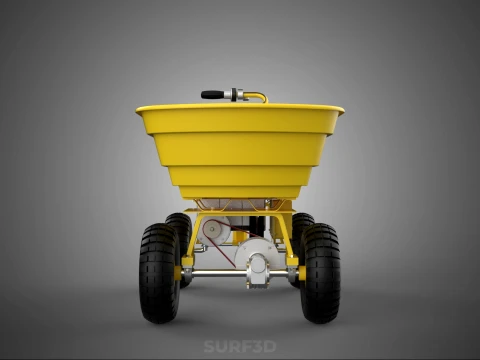
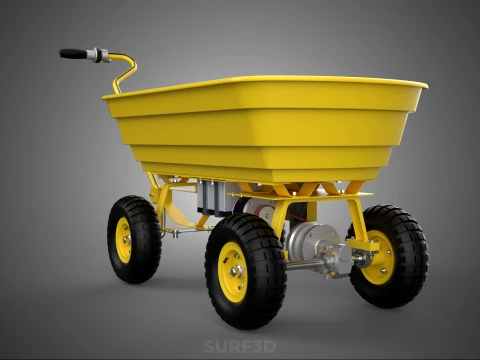
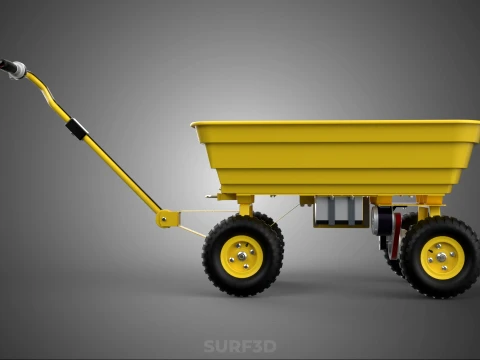
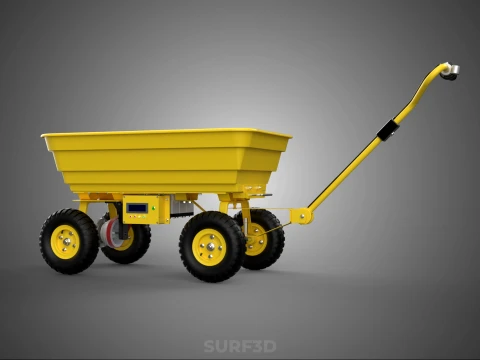
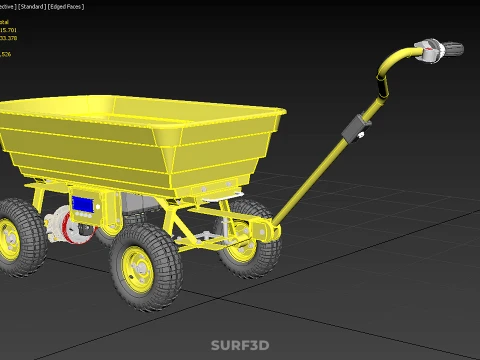
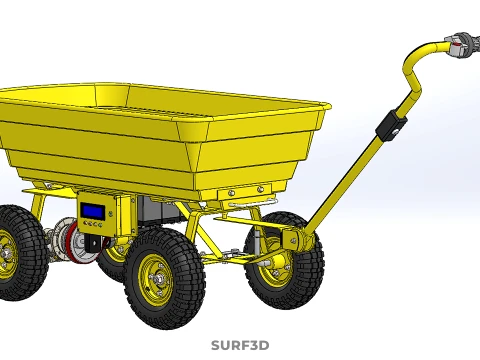
IOT AUTÔNOMO SMART ROBÔ CARRINHO CARRINHO VAGÃO CARRINHO DE MÃO JARDIM Modelo 3D

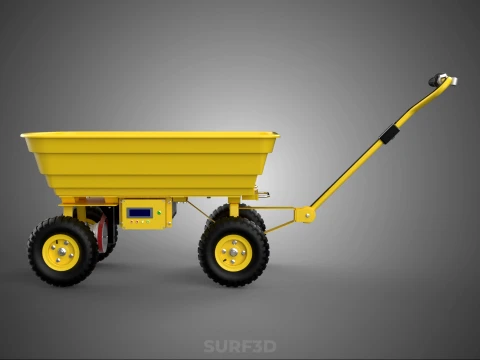
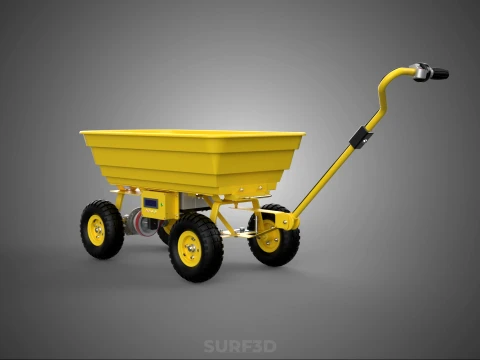
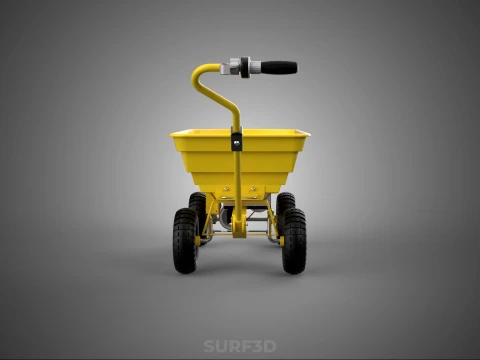
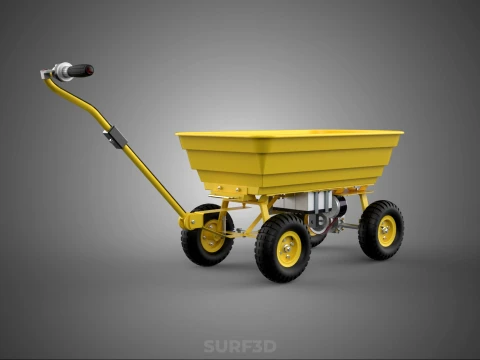
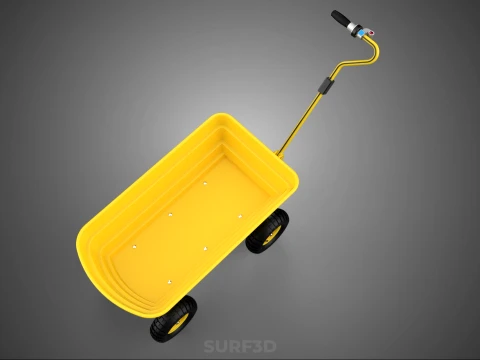
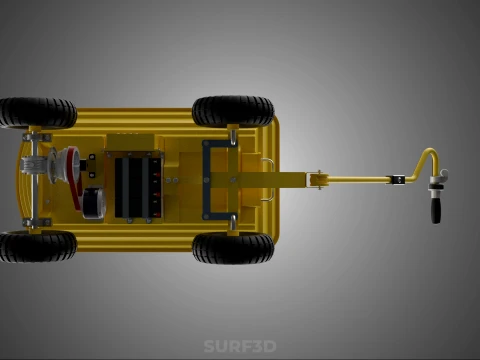
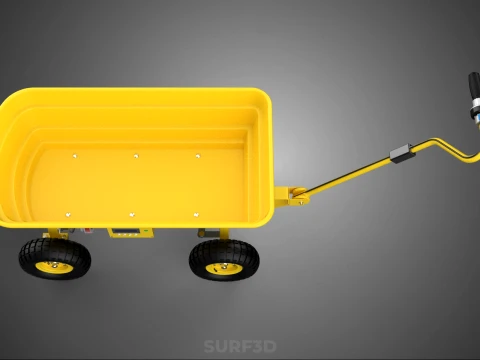
- Solicitar suporte ao produto pelo autor


- Formatos disponíveis:
- ID do Item:630274
- Data: 2026-02-25
- Polígonos:515701
- Vértices:433378
- Animados:No
- Textura:No
- Equipados:No
- Materiais:Yes
- Low-poly:No
- Coleção:No
- Mapeamento UVW:No
- Plugins Utilizados:No
- Pronto para impressão:No
- Scan 3D:No
- Conteúdo adulto:No
- PBR:No
- Treinamento de IA:No
- Geometria:Poly NURBS
- UVs não embalados:Unknown
- Visualizações:740
Descrição
High-quality 3D assets at affordable prices — trusted by designers, engineers, and creators worldwide. Made with care to be versatile, accessible, and ready for your pipeline.
Included File Formats
This model is provided in 14 widely supported formats, ensuring maximum compatibility:
• - FBX (.fbx) – Standard format for most 3D software and pipelines
• - OBJ + MTL (.obj, .mtl) – Wavefront format, widely used and compatible
• - STL (.stl) – Exported mesh geometry; may be suitable for 3D printing with adjustments
• - STEP (.step, .stp) – CAD format using NURBS surfaces
• - IGES (.iges, .igs) – Common format for CAD/CAM and engineering workflows (NURBS)
• - SAT (.sat) – ACIS solid model format (NURBS)
• - DAE (.dae) – Collada format for 3D applications and animations
• - glTF (.glb) – Modern, lightweight format for web, AR, and real-time engines
• - 3DS (.3ds) – Legacy format with broad software support
• - 3ds Max (.max) – Provided for 3ds Max users
• - Blender (.blend) – Provided for Blender users
• - SketchUp (.skp) – Compatible with all SketchUp versions
• - AutoCAD (.dwg) – Suitable for technical and architectural workflows
• - Rhino (.3dm) – Provided for Rhino users
Model Info
• - All files are checked and tested for integrity and correct content
• - Geometry uses real-world scale; model resolution varies depending on the product (high or low poly)
• • - Scene setup and mesh structure may vary depending on model complexity
• - Rendered using Luxion KeyShot
• - Affordable price with professional detailing
Buy with confidence. Quality and compatibility guaranteed.
If you have any questions about the file formats, feel free to send us a message — we're happy to assist you!
Sincerely,
SURF3D
Trusted source for professional and affordable 3D models.
More Information About 3D Model :
An IoT Autonomous Smart Robot Cart/Trolley/Wagon/Wheelbarrow Garden, often categorized as an "autonomous garden robot" or "smart utility robot for horticultural applications," represents an advanced class of mobile robotic systems engineered for automated material transport and task assistance within diverse outdoor environments, including private gardens, commercial nurseries, botanical parks, and small-scale agricultural settings. These devices integrate Internet of Things (IoT) connectivity, artificial intelligence (AI), and sophisticated robotics to operate autonomously, aiming to reduce manual labor, enhance efficiency, and provide intelligent support in garden and landscape management.
**Core Functionality and Purpose:**
The primary function of such a system is to automate the physically demanding and repetitive tasks associated with gardening and landscaping, particularly the movement of various materials. This includes transporting soil, mulch, compost, plants, gardening tools, water, fertilizers, and harvested produce. By merging the traditional utility of a cart, trolley, wagon, or wheelbarrow with autonomous navigation and intelligent decision-making, these robots optimize maintenance routines, improve productivity, and offer invaluable assistance, particularly to individuals with physical limitations or those seeking to streamline garden upkeep.
**Key Technological Components:**
1. **Autonomy and Navigation:** The autonomous capabilities are fundamental, achieved through a sophisticated array of sensors and algorithms:
* **Perception Systems:** Robots typically employ sensors such as LiDAR (Light Detection and Ranging) for 3D mapping and obstacle detection, ultrasonic sensors for localized proximity sensing, stereoscopic cameras for visual navigation, environmental feature recognition, and object identification, and Inertial Measurement Units (IMUs) for tracking orientation and motion.
* **Localization:** High-precision GPS (Global Positioning System), frequently enhanced with RTK (Real-Time Kinematic) correction, enables centimeter-level positioning accuracy within a defined operational area. Simultaneous Localization and Mapping (SLAM) algorithms allow the robot to construct a detailed map of its environment concurrently with determining its own precise location within that map.
* **Path Planning and Obstacle Avoidance:** AI-driven algorithms process sensor data to dynamically plan optimal routes, avoid static and dynamic obstacles (e.g., plants, garden furniture, humans, animals), and navigate challenging outdoor terrain, including uneven surfaces, slopes, and constrained pathways.
2. **Smart Features and Artificial Intelligence:** The "smart" aspect is derived from integrated AI and machine learning capabilities:
* **Task Management:** Robots can be programmed with specific schedules or receive dynamic instructions, utilizing AI to optimize task execution based on environmental conditions, user inputs, or pre-defined operational parameters.
* **Object Recognition:** Computer vision systems, often employing deep learning models, can identify specific plant species, weeds, gardening tools, or even assess the ripeness of produce, enabling more nuanced and precise interactions with the garden environment.
* **Adaptive Behavior:** Through continuous data collection and analysis, the robot can learn from its environment and past operations, refining its behavior for improved efficiency, safety, and task performance over time.
3. **Internet of Things (IoT) Connectivity:** IoT integration facilitates remote control, real-time monitoring, and comprehensive data exchange:
* **Wireless Communication:** Devices typically support wireless communication protocols such as Wi-Fi, Bluetooth, or cellular networks (4G/5G) for robust connectivity, enabling real-time data streaming to cloud platforms or user interfaces (e.g., smartphone applications, web portals). Low-Power Wide-Area Networks (LPWANs) like LoRaWAN may also be utilized for extended range and lower bandwidth communication in larger or more distributed garden and agricultural settings.
* **Cloud Integration:** Operational data, including navigation paths, performance metrics, and environmental sensor readings, is frequently stored and processed in cloud-based systems. This enables historical analysis, predictive maintenance scheduling, over-the-air software updates, and advanced data analytics for optimized garden management.
* **Remote Operation:** Users can monitor the robot's status, assign new tasks, define or modify operating zones, and intervene remotely via connected devices, ensuring flexible and adaptive control.
4. **Robotics and Hardware:** The physical design is optimized for resilience and functionality in outdoor garden environments:
* **Chassis and Mobility:** A robust, weather-resistant chassis is paramount, often constructed from durable materials. Mobility is typically provided by electric motors powering all-terrain wheels or tracks, designed to traverse diverse garden surfaces including soil, gravel, grass, and paved areas. Drive systems often incorporate differential steering or mecanum wheels for enhanced maneuverability.
* **Power Management:** Power is supplied by rechargeable batteries (e.g., lithium-ion), coupled with intelligent charging systems. Some models may integrate solar panels to extend operational duration or facilitate off-grid charging.
* **Payload Capacity and Modularity:** The design prioritizes stable and secure transport of varying loads. Different models offer diverse payload capacities, and many feature modular attachments or interchangeable compartments to accommodate specialized tools, containers, or sensors.
**Applications and Use Cases:**
These autonomous robots find diverse applications across various garden and landscape settings:
* **Material Transport:** Efficiently moving bags of soil, fertilizer, mulch, compost, plants, harvested produce, garden waste, or tools between different sections of a property.
Precisa de mais formatos?
Se precisar de um formato diferente, por favor abra um novo Support Ticket e solicite isso. Podemos converter modelos 3D para: .stl, .c4d, .obj, .fbx, .ma/.mb, .3ds, .3dm, .dxf/.dwg, .max. .blend, .skp, .glb. Conversão de Formato GrátisNão convertemos cenas 3D e formatos como .step, .iges, .stp, .sldprt.!
Informação de utilização
IOT AUTÔNOMO SMART ROBÔ CARRINHO CARRINHO VAGÃO CARRINHO DE MÃO JARDIM - Pode utilizar este modelo 3D isento de royalties para fins pessoais e comerciais, de acordo com a Licença Básica ou Prolongada.A Licença Básica abrange a maioria dos casos de utilização padrão, incluindo anúncios digitais, projetos de design e visualização, contas comerciais em redes sociais, aplicações nativas, aplicações web, videojogos e produtos finais físicos ou digitais (gratuitos e vendidos).
A Licença Estendida inclui todos os direitos concedidos ao abrigo da Licença Básica, sem limitações de utilização, e permite que o modelo 3D seja utilizado em projetos comerciais ilimitados ao abrigo dos termos de isenção de royalties.
Leia mais
Vocêm fornecem garantia de devolução do dinheiro?
Sim, fornecemos. Se você comprou um produto e encontrou algum erro nas renderizações ou na descrição, tentaremos corrigir o problema assim que possível. Se não pudermos corrigir o erro, cancelaremos seu pedido e você receberá seu dinheiro de volta em até 24 horas após fazer o download do item. Leia mais condições aquiPalavras-chave